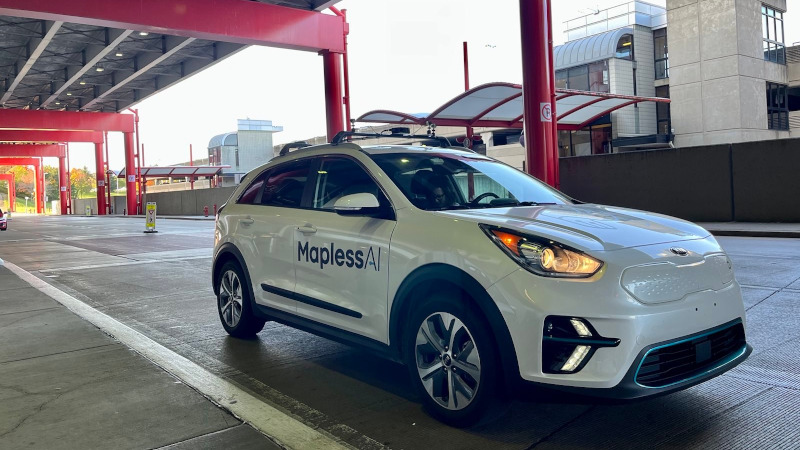
Fort Robotics announced the acquisition of Mapless AI, adding two core capabilities to its Trust Platform: remote teleoperation and onboard environmental sensing. The deal positions Fort as a unified provider of supervised autonomy infrastructure, where autonomous systems can operate with active human oversight from off-site operators monitoring multiple machines simultaneously.
Mapless AI's technology stack introduces human-in-the-loop teleoperation that allows specialists to remotely monitor and control vehicles across long distances, addressing enterprise demand for safety oversight without placing workers in hazardous zones. The onboard perception layer enables real-time environmental detection and predictive maneuvering, moving beyond reactive safety architectures to proactive hazard anticipation.
The acquisition targets industrial sectors where autonomous systems operate in high-risk or complex environments — construction, logistics, defense, and last-mile delivery. Fort's CEO Samuel Reeves framed the move as infrastructure for trustworthy physical AI: "The robotics industry is at a critical crossroads where impressive demos are everywhere, but repeatable safety remains rare."
The Mapless AI team, led by co-founders Philipp Robbel (MIT PhD, ex-Bosch, Apple, Uber, nuTonomy) and Jeffrey Kane Johnson (Indiana University PhD), brings automotive functional safety expertise and real-world robotics execution experience. Their background in safety-critical systems development aligns with Fort's positioning as the trust layer for physical AI.
The combined platform decouples human oversight from physical proximity to risk, enabling supervised autonomy at scale. A single off-site operator can now monitor multiple autonomous vehicles in real time, maintaining meaningful control without direct exposure to operational hazards.