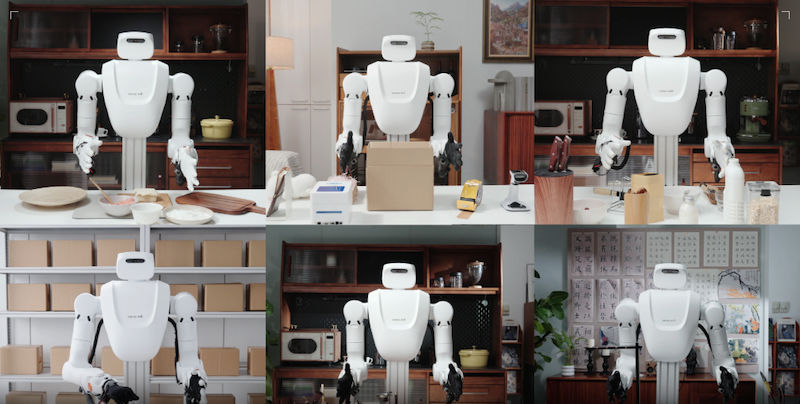
Nature Will, a Physical AI lab, announced Natura-1, a 50-billion-parameter mixture-of-experts model designed for dexterous hand control. The model was pre-trained on over 1 million hours of egocentric human hand data and operates at a 100-millisecond control loop, unifying vision, language, and fine motor action.
Natura-1's architecture allows it to follow complex natural language instructions and adapt to changing task conditions in real time. The model handles multi-object reasoning, spatial constraints, and sustained workflows — capabilities that have eluded previous robotics foundation models focused on coarser manipulation or single-task domains.
CEO Ning Ding positions Natura-1 as infrastructure for scaling human experience into physical action. The company's thesis: general-purpose AI for the physical world requires dexterous hands, and those capabilities must be learned jointly across language, vision, and action rather than bolted together from separate subsystems.
The release follows a growing pattern of foundation models extending into robotics — OpenAI's partnership with Figure, Google DeepMind's RT-X work, and Tesla's Optimus neural net updates. Nature Will's scale (50B parameters) and focus on fine manipulation distinguish it from competitors still working with simpler grippers or lower-parameter models.
Deployment details remain sparse. Nature Will did not disclose hardware partners, target industries, or commercial timelines. The model's reliance on egocentric human data raises questions about transferability to non-humanoid form factors and whether fine-tuning will be required for specific domains like assembly, surgery, or food handling.


