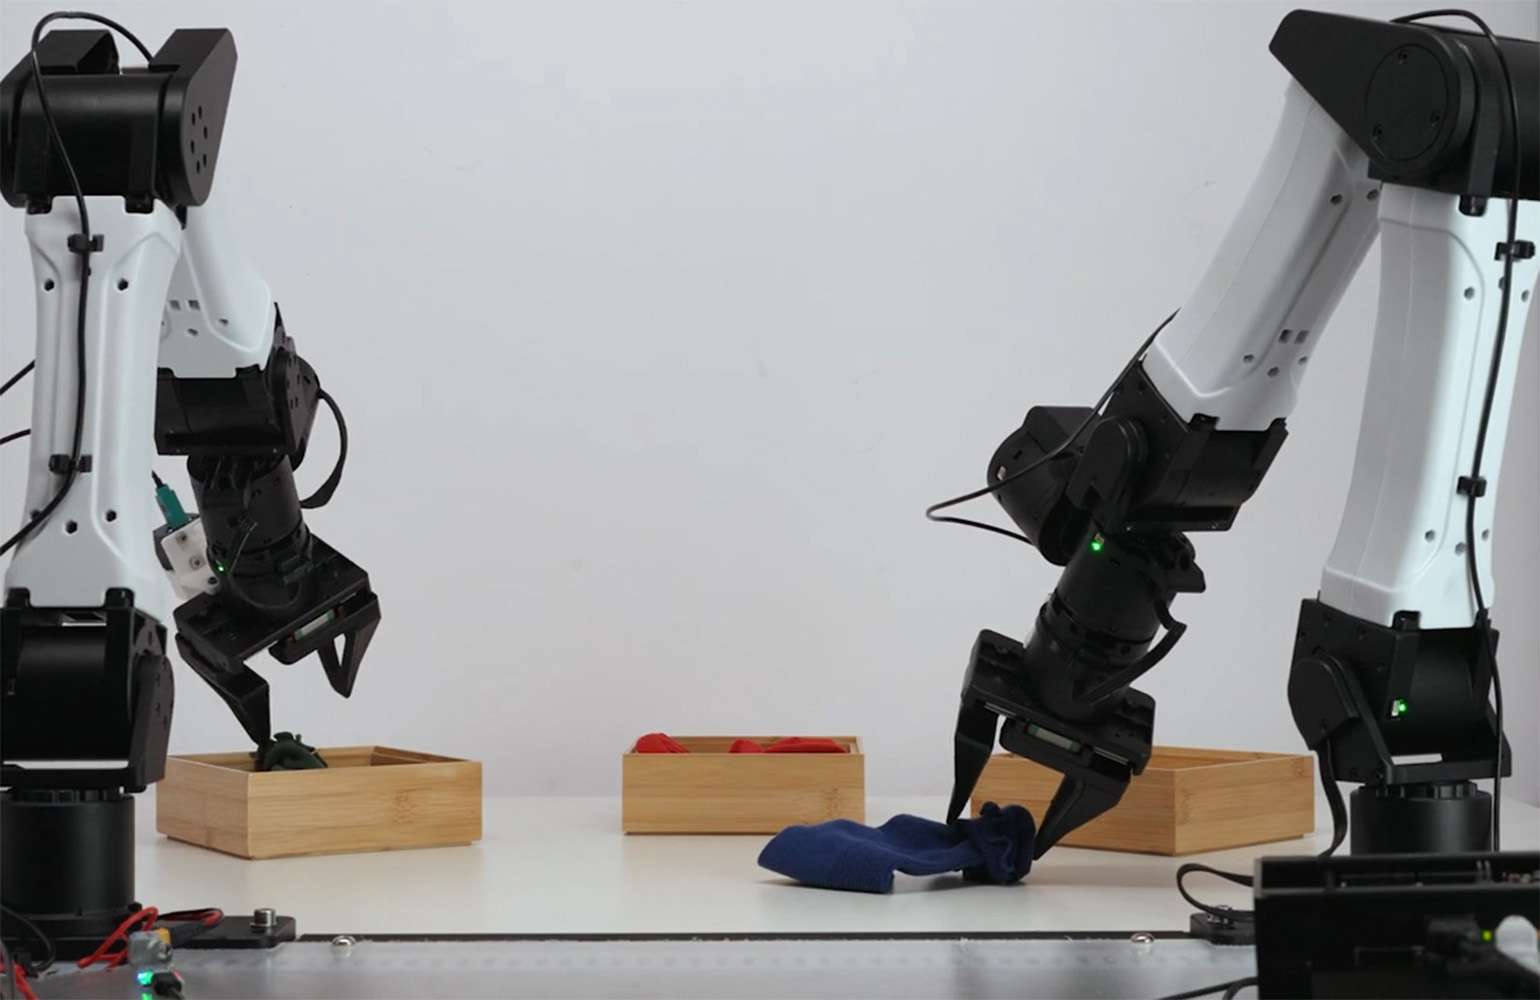
Runway AI released Praxis-1, a 27-billion-parameter world action model, with full open weights under Apache 2.0. The model is available on GitHub, Hugging Face, and vLLM-Omni, with support for both full fine-tuning and LoRA adaptation. Launch partners Noble Machines, Standard Bots, and Ultra have deployed it on legged humanoids, six-axis industrial arms, and dual-arm warehouse robots since September.
The model's architecture is a mixture-of-experts diffusion transformer that predicts video and actions together. By training on large-scale web video to understand how physical tasks unfold, Praxis-1 gains transferable knowledge before fine-tuning on hardware-specific data. On NVIDIA's RoboLab-120 benchmark, it achieved 46.2% success across 1,200 episodes, ranking fifth overall and first among open-source policies.
Cross-embodiment generalization is a key capability. A single Praxis-1 checkpoint adapted to Noble's humanoid for warehouse plank handling, Standard Bots' arms for machine tending, and Ultra's dual-arm stations for order packing. When fine-tuned on Google's RT-1 robot — an embodiment not in its training data — Praxis-1 reached 80.0% success on SimplerEnv, compared to RT-1's original 52.4%.
Runway framed the open-weight release as strategic infrastructure for U.S. competitiveness in Physical AI. Head of robotics Andy Chen stated that regaining manufacturing leadership and securing supply chains will require interoperability that closed models don't provide. The company is now focused on scaling real-world deployments with partners in warehouses, factories, and industrial sites.


